01 / PHYSICALSystems that move.ROS2, hardware integration, and controlled motion.
02 / EVIDENCESystems that explain.Diagnostics, stale-state handling, and verifiable records.
03 / DELIVERYSystems that ship.Websites, client workflows, and practical software.
FEATURED SYSTEMS / OPEN ON ARRIVAL
DIAGNOSTICS LAB / SIMULATED SAMPLES
AGE 0.2s
When fresh data goes stale, the monitor should say so.
joint_state / elbowNOMINALage: 0.2s
Current sample is inside the expected freshness window.
01ACTIVE
WayBionic — ROS2 Ground Station
A ground station for remote visibility and control of a surgical robotic arm, with motion tests publishing to a simulated joint-state driver.
MY CONTRIBUTIONBuilt the movement-test panels and diagnostics behavior that surfaces stale joint values and errors inside RViz; changed the arm wiring to match the control code.
ROS2 / C++ / PYTHON / RVIZ / SIMULATION
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
OPERATORRUN / HOME / STOP
→
GROUND STATIONROS2 COMMAND
→
JOINT DRIVERSIMULATED STATE
DIAGNOSTICSAGE / STALE / FUTURE
RVIZMONITOR + MODEL
This is a communication model, not a claim that every displayed path is the final production architecture.
A sequence for building robotics skill in simulation first: imitation learning, reinforcement learning, then navigation and SLAM.
MY CONTRIBUTIONChose a simulation-first sequence to build robotics skill without purchasing hardware up front.
LEROBOT / MUJOCO / ISAAC LAB / NAV2
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
MUJOCOIMITATION
→
ISAAC LABRL LOCOMOTION
→
NAV2 / SLAMREAL NAVIGATION
This is a communication model, not a claim that every displayed path is the final production architecture.
03SHIPPED
HVAC Express
A real web presence and technical infrastructure for a family-run Calgary heating and cooling company.
MY CONTRIBUTIONDesigned, built, and maintain the live site end-to-end, including token-based CSS architecture, Hostinger hosting, SEO work, and security remediation.
WORDPRESS / INFRASTRUCTURE
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CALGARY CUSTOMERSEARCH / CONTACT / BOOKING
↓
HVAC EXPRESS SITEWORDPRESS / PHP / HTML + CSS
↓
HOSTINGERDOMAIN + INFRASTRUCTURE
LEAD SYSTEMSEO + INBOUND DEMAND
This is a communication model, not a claim that every displayed path is the final production architecture.
A wireless rover that detects and avoids obstacles with independent left and right motor control and sonar-based distance sensing.
MY CONTRIBUTIONProgrammed the control behavior and structured the Java class hierarchy around movement, sensing, acceleration, and challenge logic.
JAVA / PHIDGETS SDK / CS30 CAPSTONE
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
SONARDISTANCE INPUT
→
CONTROL LOGICOBSTACLE DECISION
→
LEFT DCMOTOR
RIGHT DCMOTOR
This is a communication model, not a claim that every displayed path is the final production architecture.
05ACTIVE
Chinook Clean
A power-washing business Ajmal owns and runs, built around direct customer work, service delivery, and practical ownership.
MY CONTRIBUTIONOwns the business and handles the work from customer conversations through field execution.
ENTREPRENEURSHIP / FIELD OPERATIONS / CUSTOMER WORK
06ACTIVE
Physical AI BlackBox
A secure, local-first evidence stack for recording what a physical AI system was told, commanded, and observed.
PYTHON / CBOR2 / CRYPTOGRAPHY / LOCAL SYSTEMS
07IN PROGRESS
Teach to Game
A local reinforcement-learning lab where an agent learns games from explicit goals, target scores, and user-provided reward signals.
PYTHON / REINFORCEMENT LEARNING / PLAYWRIGHT / LOCAL LAB
08IN PROGRESS
Soccer Intelligence Lab
An Azure-ready workspace for turning synthetic football events into explainable match intelligence and personalized stories.
NEXT.JS / REACT / TYPESCRIPT / SYNTHETIC EVENTS
VERIFIED STACK / PUBLIC WORKLOCAL ASSET INDEX / 08
PYTHON
C++
ROS2
GITHUB
WORDPRESS
ARDUINO
THREE.JS
ASTRO
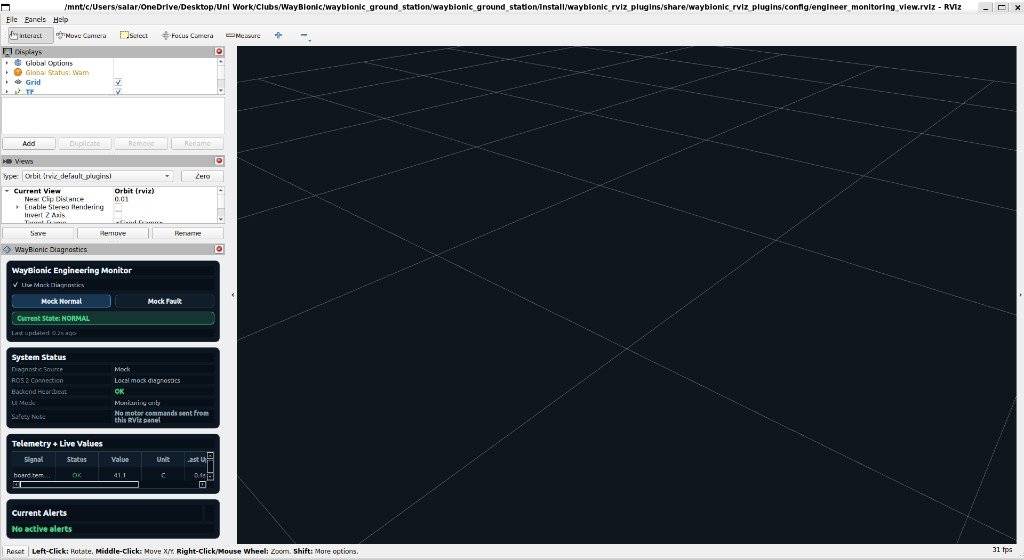
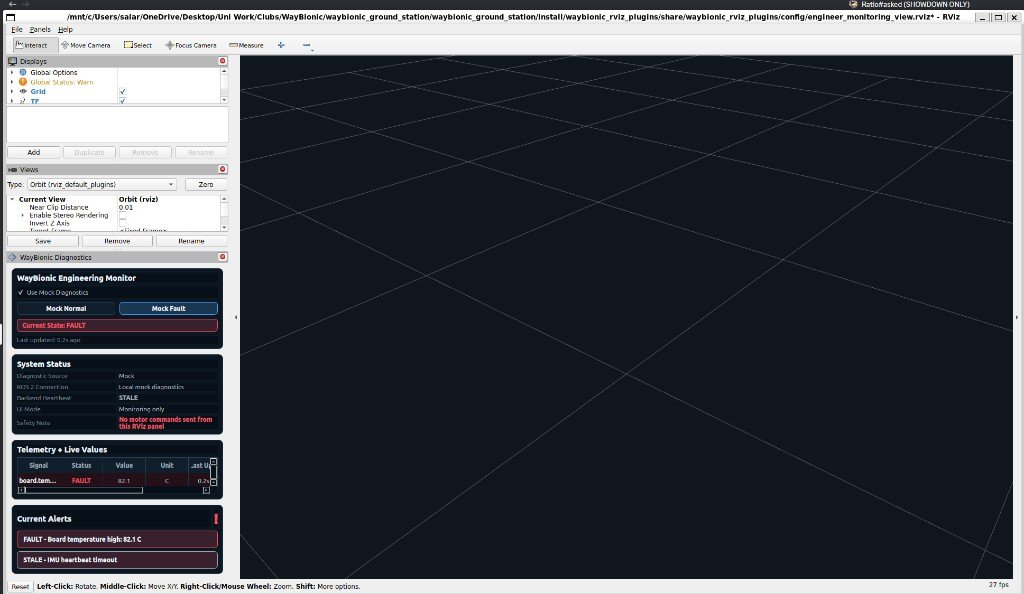
WAYBIONIC / ENGINEERING MONITOR
ROBOTICSROS2 / RVIZENGINEERING MONITOR
UCalgary CLUB / ROS2 GROUND STATION / ACTIVE
I built the movement panels and the errors they surface.
The monitor checks joint and system state, then reflects stale values and errors inside RViz instead of hiding uncertainty. Motion tests stay controlled until the real arm is ready.
MOCK NORMAL / RVIZMOCK FAULT / STALE STATE
OPTIONAL WEBGL MODULE / SIMULATION ONLY
Drag the target. Watch the arm solve.
FABRIK / 8 PASSESLOCAL WEBGL
MODESIMULATION
JOINTS4 JOINT OLD ARM
TARGETTRACKING
LIMITSNOMINAL
Nothing is connected to a robot. This represents the old-arm motion test; drag the cyan target to explore reach. The source bridge reports 0–270° physical ranges, while calibration remains a hardware concern.
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
OPERATORRUN / HOME / STOP
→
GROUND STATIONROS2 COMMAND
→
JOINT DRIVERSIMULATED STATE
DIAGNOSTICSAGE / STALE / FUTURE
RVIZMONITOR + MODEL
This is a communication model, not a claim that every displayed path is the final production architecture.
JOINT STATUS / SIMULATION ONLY
BASE_YAW
Real joint names, limits, and units pending team confirmation.
A local-first evidence stack for physical AI systems.
BlackBox is a tamper-evident recorder concept and working Python project for capturing what an AI system was told, what it commanded, and what physically happened.
Conceptual browser demo. Not production evidence and not a cryptographic claim about this website.
PUBLIC VIEW / HIGH-LEVEL ARCHITECTURE ONLY / SENSITIVE DETAILS OMITTED
CHINOOK CLEAN / BUSINESS LOG
BUSINESSFIELD OPERATIONSACTIVE
ACTIVE BUSINESS / OWNED + OPERATED / FIELD WORK
A business where the result is visible.
Chinook Clean is a power-washing business Ajmal owns and runs. The work is direct, physical, and customer-facing: the operating system is the conversation, the schedule, the equipment, and the finished surface.
01 / OWNERSHIPCustomer conversations, decisions, and responsibility stay close to the work.
02 / FIELD DELIVERYService quality is measured on-site by the result the customer can see.
03 / NEXT SYSTEMBuild repeatable workflows without losing the human part of the service.
PUBLIC SUMMARY / ACTIVE BUSINESS / DETAILS INTENTIONALLY COMPACT
TEACH TO GAME / RL LAB
AI LABREINFORCEMENT LEARNINGLOCAL
LOCAL REINFORCEMENT LEARNING / PYTHON / PLAYWRIGHT
Teaching an agent what success means.
Teach to Game is a local reinforcement-learning lab where goals, target scores, and reward signals are explicit. Snake and runner practice games work on a fresh laptop without sending training data to a cloud service.
GAME STATE→POLICY→ACTION→REWARD
INTERACTIVE / TABULAR Q-LEARNING
Reward Lab 01
READY / UNTRAINED
SCORE 0BEST 0EPISODES 0
The agent earns a reward for reaching food, loses reward for collisions, and learns which turns work. Train it, then watch its current policy.
LAST 10 EPISODES—Mean reward / episode
SMALL TEACHING MODEL / REWARD VALUES ARE EDITABLE / TRAINING RUNS LOCALLY IN THIS TAB
LOCAL LAB / USER-PROVIDED ADAPTERS / ONLINE ANTI-CHEAT GAMES OUT OF SCOPE
SOCCER INTELLIGENCE / EVENT LAB
SPORTS INTELLIGENCESYNTHETIC EVENTSIN PROGRESS
NEXT.JS / REACT / TYPESCRIPT / SYNTHETIC EVENTS
Turning events into match intelligence.
An Azure-ready workspace for turning football-realistic events into explainable match intelligence and personalized stories while keeping raw events, derived state, explanations, and presentation payloads separate.
EVENTSsynthetic stream
→
STATEmetrics + context
→
STORYgrounded insight
SYNTHETIC DATA / EVIDENCE-GROUNDED NARRATIVE / PROVIDER-NEUTRAL PIPELINE
ROVER / CS30 CAPSTONE
HARDWAREJAVA / SONARCAPSTONE
JAVA / PHIDGETS SDK / HARDWARE CONTROL
Teaching software to notice obstacles.
A wireless rover with independent left/right DC motor control and sonar-based distance sensing. The code separates movement, sensing, acceleration, and challenge logic.
SONAR→DECISION→MOTOR CONTROL
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
SONARDISTANCE INPUT
→
CONTROL LOGICOBSTACLE DECISION
→
LEFT DCMOTOR
RIGHT DCMOTOR
This is a communication model, not a claim that every displayed path is the final production architecture.
When I am not building or debugging, I am usually somewhere between a Star Wars Legends rabbit hole, a very fast car, a competitive match, and a Banff trail.
✦ Star Wars / Legends + canon✦ Cars that are extremely fast and cool✦ Valorant / Geometry Dash / Brawl Stars✦ Banff trails / Johnston Canyon / Big Beehive / Sarail Ridge
SYSTEM INFO / AJMAL KHIDRI
PROFILERECRUITER VIEWOPEN TO WORK
PUBLIC PROFILE / RECRUITER VIEW
Ajmal Khidri Computer Science student.
LOCATIONCalgary, Alberta
EDUCATIONUniversity of Calgary / B.Sc. Computer Science / Expected 2029
Source-backed physical input range: 0–270° for each old-arm servo. Home and direction values are shown from the local bridge configuration.
old_arm_base_yaw_joint0–270° / home 90° / dir +
old_arm_shoulder_pitch_joint0–270° / home 35° / dir −
old_arm_elbow_pitch_joint0–270° / home 151.5° / dir +
old_arm_wrist_roll_joint0–270° / home 27.5° / dir +
LOCAL UI DEMO / NO HARDWARE COMMANDS ARE SENT
FILES / HOME AJ
FILESLOCAL VFSHOME / AJ
INDEXEDDB / LOCAL VIRTUAL FILESYSTEM
/home/aj persistent archive.
AjmalOS filesystem ready. Type help.
LOCAL ONLY / PERSISTS IN THIS BROWSER / NO UPLOADS
RESEARCH / PERSONAL
STUDYPHYSICS / FEASIBILITYPUBLIC SAFE
PERSONAL TECHNICAL RESEARCH / PUBLIC STUDY
Science fiction with numbers attached.
A feasibility assessment for a metre-scale confined-plasma cutting blade, modelled as a sheared-flow-stabilized screw pinch. The study separates what current plasma physics supports from the technology gaps that still block a handheld system.
PHYSICSConfined plasma / Z-pinch feasibility
GAPS IDENTIFIEDCompact power density and ambient-air exclusion
FORMAT27-page design study and preprint
WHY IT MATTERSCuriosity, modelling, and honest limits over sci-fi handwaving
PERSONAL RESEARCH / NOT A PRODUCT CLAIM
BUILD NOTES / CURRENT
ROADMAPBUILD LOGNEXT ITERATION
LOCAL NOTES / PUBLIC-SAFE SUMMARY
What is being built next.
WayBionicMove from controlled simulation toward the fully working arm and the physical Arduino bridge.
Robotics roadmapMuJoCo imitation learning → Isaac Lab locomotion → ROS2 Nav2 and SLAM.
 MY WORK / FILE EXPLORER


 WAYBIONIC / ENGINEERING MONITOR
 BLACKBOX / PROJECT NOTES
 CHINOOK CLEAN / BUSINESS LOG
 TEACH TO GAME / RL LAB
 SOCCER INTELLIGENCE / EVENT LAB
 ROVER / CS30 CAPSTONE
 RESUME / AJMAL KHIDRI
 ABOUT AJ / PERSONAL
 SYSTEM INFO / AJMAL KHIDRI
 WORK HISTORY / TIMELINE
 SKILLS / TOOLBOX
 ROS2 / GRAPH VIEWER
 SYSTEM MONITOR
 OLD ARM / JOINT PANEL
 FILES / HOME AJ
 RESEARCH / PERSONAL
 BUILD NOTES / CURRENT
 TERMINAL / AJMALOS
 MEDIA PLAYER / WAYBIONIC
 SYSTEM RESTORE / AJMALOS
 RECYCLE BIN
 HVAC / COMFORT CALCULATOR
 CALCULATOR
 AJMAL BROWSER