AJMALOS
AJMALOS 1.0 / LOCAL ARCHIVE / 2026
MY WORK / FILE EXPLORER
FILE   EDIT   VIEW   HELP LOCAL ARCHIVE / 04 ITEMS

AJMAL KHIDRI / WORKING SYSTEMS

Things I have
built or touched.

A personal archive of physical systems, software, and the businesses that taught me to keep things running.

01ACTIVE

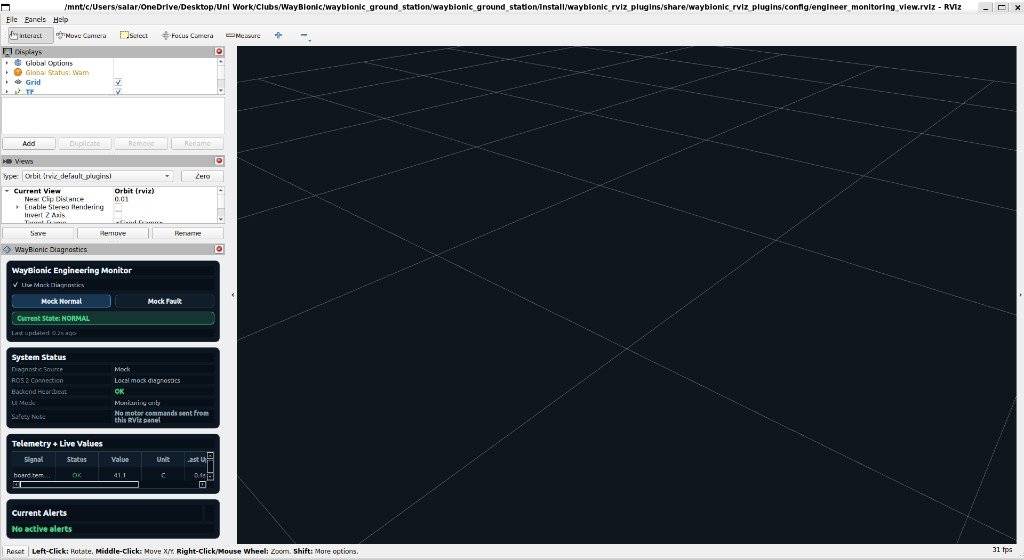
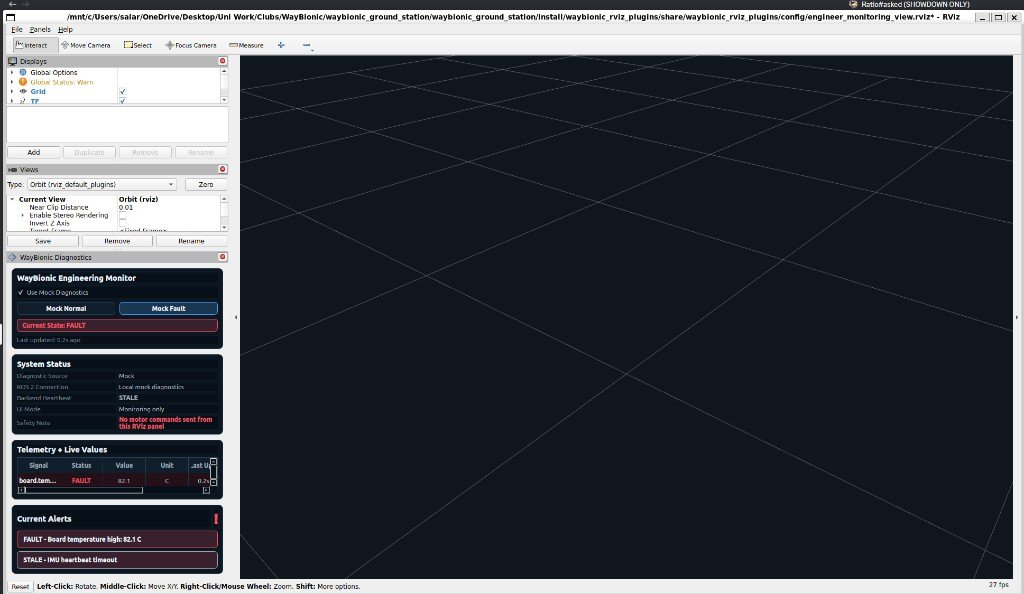
WayBionic — ROS2 Ground Station

A ground station for remote visibility and control of a surgical robotic arm, with motion tests publishing to a simulated joint-state driver.

MY CONTRIBUTIONBuilt the movement-test panels and diagnostics behavior that surfaces stale joint values and errors inside RViz; changed the arm wiring to match the control code.

ROS2 / C++ / PYTHON / RVIZ / SIMULATION
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
OPERATORRUN / HOME / STOP
→
GROUND STATIONROS2 COMMAND
→
JOINT DRIVERSIMULATED STATE
DIAGNOSTICSAGE / STALE / FUTURE
RVIZMONITOR + MODEL

This is a communication model, not a claim that every displayed path is the final production architecture.
OPEN SOURCE ↗
02IN PROGRESS

Personal Robotics Roadmap

A sequence for building robotics skill in simulation first: imitation learning, reinforcement learning, then navigation and SLAM.

MY CONTRIBUTIONChose a simulation-first sequence to build robotics skill without purchasing hardware up front.

LEROBOT / MUJOCO / ISAAC LAB / NAV2
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
MUJOCOIMITATION
→
ISAAC LABRL LOCOMOTION
→
NAV2 / SLAMREAL NAVIGATION

This is a communication model, not a claim that every displayed path is the final production architecture.

03SHIPPED

HVAC Express

A real web presence and technical infrastructure for a family-run Calgary heating and cooling company.

MY CONTRIBUTIONDesigned, built, and maintain the live site end-to-end, including token-based CSS architecture, Hostinger hosting, SEO work, and security remediation.

WORDPRESS / INFRASTRUCTURE
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CALGARY CUSTOMERSEARCH / CONTACT / BOOKING
↓
HVAC EXPRESS SITEWORDPRESS / PHP / HTML + CSS
↓
HOSTINGERDOMAIN + INFRASTRUCTURE
LEAD SYSTEMSEO + INBOUND DEMAND

This is a communication model, not a claim that every displayed path is the final production architecture.

OPEN SOURCE ↗
04SHIPPED

Autonomous Obstacle-Avoiding Rover

A wireless rover that detects and avoids obstacles with independent left and right motor control and sonar-based distance sensing.

MY CONTRIBUTIONProgrammed the control behavior and structured the Java class hierarchy around movement, sensing, acceleration, and challenge logic.

JAVA / PHIDGETS SDK / CS30 CAPSTONE
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
SONARDISTANCE INPUT
→
CONTROL LOGICOBSTACLE DECISION
→
LEFT DCMOTOR
RIGHT DCMOTOR

This is a communication model, not a claim that every displayed path is the final production architecture.

◉◖))▰▣00:00
POWER / ONLINE