A personal archive of physical systems, software, and the businesses that taught me to keep things running.
01 / PHYSICALSystems that move.ROS2, hardware integration, and controlled motion.
02 / EVIDENCESystems that explain.Diagnostics, stale-state handling, and verifiable records.
03 / DELIVERYSystems that ship.Websites, client workflows, and practical software.
FEATURED SYSTEMS / OPEN ON ARRIVAL
DIAGNOSTICS LAB / SIMULATED SAMPLES
AGE 0.2s
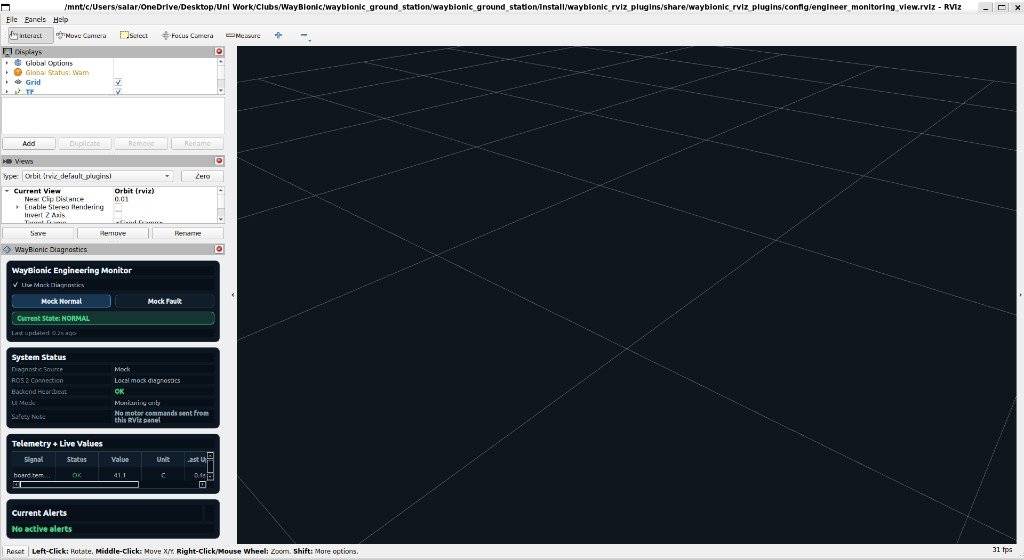
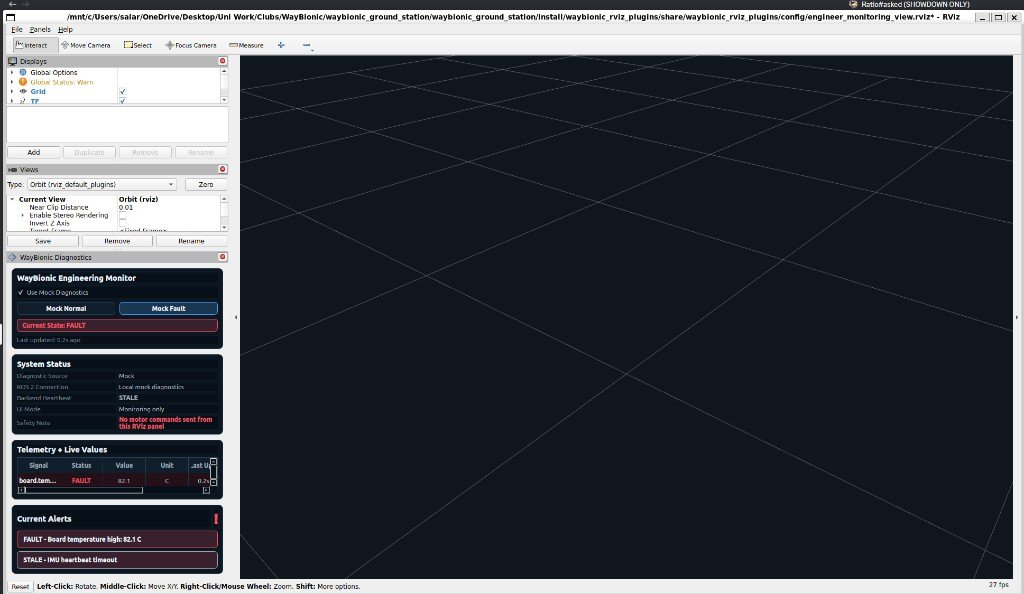
When fresh data goes stale, the monitor should say so.
joint_state / elbowNOMINALage: 0.2s
Current sample is inside the expected freshness window.
01ACTIVE
WayBionic — ROS2 Ground Station
A ground station for remote visibility and control of a surgical robotic arm, with motion tests publishing to a simulated joint-state driver.
MY CONTRIBUTIONBuilt the movement-test panels and diagnostics behavior that surfaces stale joint values and errors inside RViz; changed the arm wiring to match the control code.
ROS2 / C++ / PYTHON / RVIZ / SIMULATION
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CONCEPTUAL MODEL
OPERATORRUN / HOME / STOP
→
GROUND STATIONROS2 COMMAND
→
JOINT DRIVERSIMULATED STATE
DIAGNOSTICSAGE / STALE / FUTURE
RVIZMONITOR + MODEL
This is a communication model, not a claim that every displayed path is the final production architecture.
A sequence for building robotics skill in simulation first: imitation learning, reinforcement learning, then navigation and SLAM.
MY CONTRIBUTIONChose a simulation-first sequence to build robotics skill without purchasing hardware up front.
LEROBOT / MUJOCO / ISAAC LAB / NAV2
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CONCEPTUAL MODEL
MUJOCOIMITATION
→
ISAAC LABRL LOCOMOTION
→
NAV2 / SLAMREAL NAVIGATION
This is a communication model, not a claim that every displayed path is the final production architecture.
03SHIPPED
HVAC Express
A real web presence and technical infrastructure for a family-run Calgary heating and cooling company.
MY CONTRIBUTIONDesigned, built, and maintain the live site end-to-end, including token-based CSS architecture, Hostinger hosting, SEO work, and security remediation.
WORDPRESS / INFRASTRUCTURE
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CONCEPTUAL MODEL
CALGARY CUSTOMERSEARCH / CONTACT / BOOKING
↓
HVAC EXPRESS SITEWORDPRESS / PHP / HTML + CSS
↓
HOSTINGERDOMAIN + INFRASTRUCTURE
LEAD SYSTEMSEO + INBOUND DEMAND
This is a communication model, not a claim that every displayed path is the final production architecture.
A wireless rover that detects and avoids obstacles with independent left and right motor control and sonar-based distance sensing.
MY CONTRIBUTIONProgrammed the control behavior and structured the Java class hierarchy around movement, sensing, acceleration, and challenge logic.
JAVA / PHIDGETS SDK / CS30 CAPSTONE
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CONCEPTUAL MODEL
SONARDISTANCE INPUT
→
CONTROL LOGICOBSTACLE DECISION
→
LEFT DCMOTOR
RIGHT DCMOTOR
This is a communication model, not a claim that every displayed path is the final production architecture.
⚙WAYBIONIC / ENGINEERING MONITOR
CONCEPTUAL MODEL
CONCEPT MODEL / WAYBIONIC / LIVE VIEW
LIVE APP MODULE / WAYBIONICSTANDBY
CONCEPTUAL / LOCAL SIMULATION
UCalgary CLUB / ROS2 GROUND STATION / ACTIVE
I built the movement panels and the errors they surface.
The monitor checks joint and system state, then reflects stale values and errors inside RViz instead of hiding uncertainty. Motion tests stay controlled until the real arm is ready.
MOCK NORMAL / RVIZMOCK FAULT / STALE STATE
OPTIONAL WEBGL MODULE / SIMULATION ONLY
Drag the target. Watch the arm solve.
FABRIK / 8 PASSESLOCAL WEBGL
MODESIMULATION
JOINTS4 JOINT OLD ARM
TARGETTRACKING
LIMITSNOMINAL
Nothing is connected to a robot. This represents the old-arm motion test; drag the cyan target to explore reach. The source bridge reports 0–270° physical ranges, while calibration remains a hardware concern.
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CONCEPTUAL MODEL
OPERATORRUN / HOME / STOP
→
GROUND STATIONROS2 COMMAND
→
JOINT DRIVERSIMULATED STATE
DIAGNOSTICSAGE / STALE / FUTURE
RVIZMONITOR + MODEL
This is a communication model, not a claim that every displayed path is the final production architecture.
JOINT STATUS / SIMULATION ONLY
BASE_YAW
Real joint names, limits, and units pending team confirmation.
A local-first evidence stack for physical AI systems.
BlackBox is a tamper-evident recorder concept and working Python project for capturing what an AI system was told, what it commanded, and what physically happened.
Conceptual browser demo. Not production evidence and not a cryptographic claim about this website.
PUBLIC VIEW / HIGH-LEVEL ARCHITECTURE ONLY / SENSITIVE DETAILS OMITTED
▤ROVER / CS30 CAPSTONE
CONCEPTUAL MODEL
CONCEPT MODEL / ROVER / LIVE VIEW
LIVE APP MODULE / ROVERSTANDBY
CONCEPTUAL / LOCAL SIMULATION
JAVA / PHIDGETS SDK / HARDWARE CONTROL
Teaching software to notice obstacles.
A wireless rover with independent left/right DC motor control and sonar-based distance sensing. The code separates movement, sensing, acceleration, and challenge logic.
SONAR→DECISION→MOTOR CONTROL
CONCEPTUAL / MOCK DIAGRAM● SIGNAL PATH
CONCEPTUAL MODEL
SONARDISTANCE INPUT
→
CONTROL LOGICOBSTACLE DECISION
→
LEFT DCMOTOR
RIGHT DCMOTOR
This is a communication model, not a claim that every displayed path is the final production architecture.
When I am not building or debugging, I am usually somewhere between a Star Wars Legends rabbit hole, a very fast car, a competitive match, and a Banff trail.
✦ Star Wars / Legends + canon✦ Cars that are extremely fast and cool✦ Valorant / Geometry Dash / Brawl Stars✦ Banff trails / Johnston Canyon / Big Beehive / Sarail Ridge
ⓘSYSTEM INFO / AJMAL KHIDRI
CONCEPTUAL MODEL
CONCEPT MODEL / ROADMAP / LIVE VIEW
LIVE APP MODULE / SYSTEMSTANDBY
CONCEPTUAL / LOCAL SIMULATION
PUBLIC PROFILE / RECRUITER VIEW
Ajmal Khidri Computer Science student.
LOCATIONCalgary, Alberta
EDUCATIONUniversity of Calgary / B.Sc. Computer Science / Expected 2029
A feasibility assessment for a metre-scale confined-plasma cutting blade, modelled as a sheared-flow-stabilized screw pinch. The study separates what current plasma physics supports from the technology gaps that still block a handheld system.
PHYSICSConfined plasma / Z-pinch feasibility
GAPS IDENTIFIEDCompact power density and ambient-air exclusion
FORMAT27-page design study and preprint
WHY IT MATTERSCuriosity, modelling, and honest limits over sci-fi handwaving
PERSONAL RESEARCH / NOT A PRODUCT CLAIM
▤BUILD NOTES / CURRENT
CONCEPTUAL MODEL
CONCEPT MODEL / ROADMAP / LIVE VIEW
LIVE APP MODULE / NOTESSTANDBY
CONCEPTUAL / LOCAL SIMULATION
LOCAL NOTES / PUBLIC-SAFE SUMMARY
What is being built next.
WayBionicMove from controlled simulation toward the fully working arm and the physical Arduino bridge.
Robotics roadmapMuJoCo imitation learning → Isaac Lab locomotion → ROS2 Nav2 and SLAM.